Intelligent Mobile Manipulation for Dynamic Environments with Seeed reComputer J4012
Modern service robots are increasingly expected to operate in real-world environments that are not controlled, predictable, or static. Beyond simple navigation, today’s autonomous systems must perceive their surroundings, synchronize multiple sensing modalities, manipulate physical objects, and interact naturally with people — all under tight latency and reliability constraints. The challenge is not only building each of these capabilities, but integrating them into a single, unified platform that performs reliably at the edge.
Vedya Labs explores this challenge through a unified mobile manipulation platform built around the Seeed Studio reComputer J4012, powered by NVIDIA Jetson Orin NX 16GB, which serves as the central edge AI computer for navigation, perception, manipulation, and human-machine interaction.
The Challenge: Real-World Mobile Manipulation
In dynamic service and logistics environments — such as large-scale laundromats or flexible warehouses — automation faces a triad of complexity that conventional robotic stacks struggle to address.
- Navigating unpredictable spaces filled with moving people, carts, and obstacles requires robust SLAM that remains stable when visual features change with lighting conditions.
- Performing delicate physical tasks such as sorting soft textiles or handling irregular packages demands precise visual feedback, real-time depth estimation, and dexterous manipulation.
- Operating in noisy industrial settings makes traditional touchscreens impractical, while cloud-dependent voice assistants often fail to recognize commands under machinery noise.
A leading service robotics integrator needed a single hardware platform that could seamlessly integrate navigation, manipulation, and intuitive interaction — without relying on cloud connectivity.
reComputer J4012 as the Central Edge AI Platform
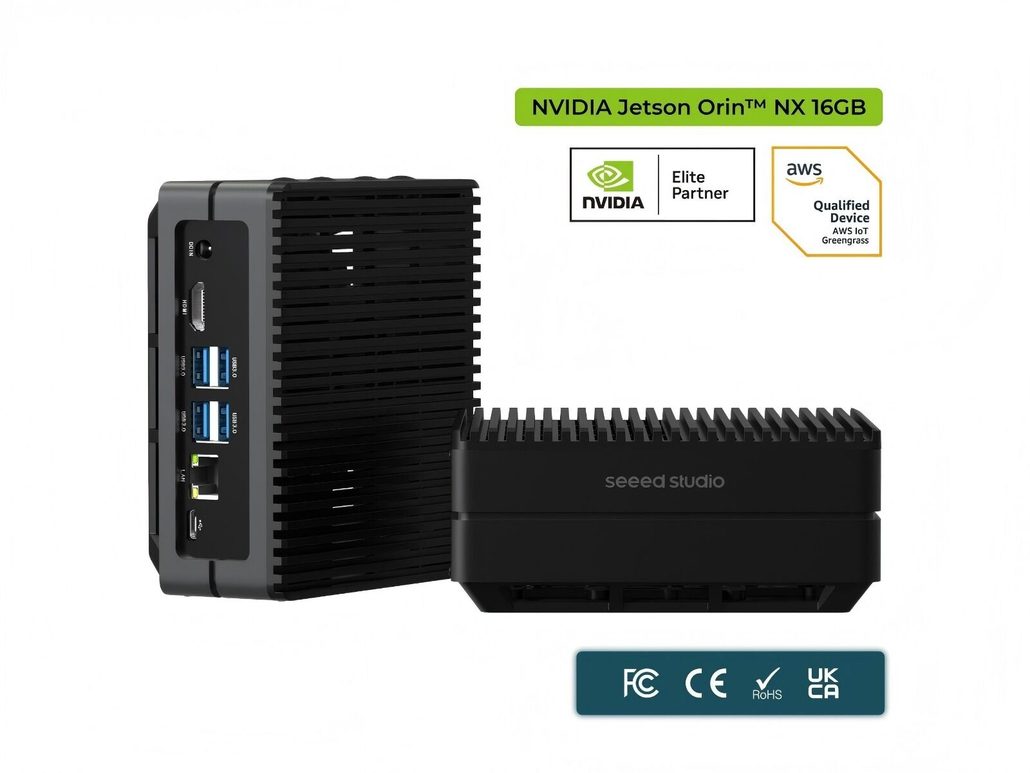
The reComputer J4012 provides the central computing platform for Vedya Labs’ mobile manipulation system.
Built around NVIDIA Jetson Orin NX 16GB, it delivers up to 157 TOPS of AI performance for computer vision, sensor fusion, and real-time control.
Beyond computing performance, the system provides interfaces including Gigabit Ethernet, USB, M.2, CAN, UART, and I²C, making it easier to connect LIDAR, IMUs, cameras, robotic arms, and additional AI accelerators through the ROS 2 ecosystem.
For this deployment, the J4012 brings several key functions together:
Perceive → Navigate → Manipulate → Interact
Instead of building these capabilities from separate modules, developers can use the reComputer J4012 as an integrated Jetson edge AI platform for service robotics.
A Heterogeneous Edge AI Architecture
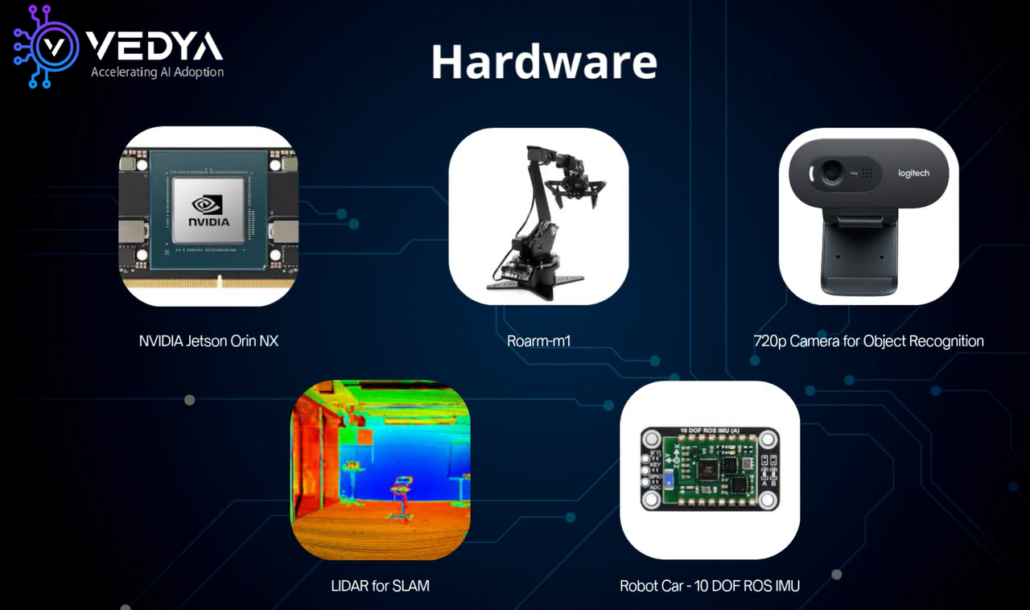
Vedya Labs distributes different workloads across different processing stages on the J4012.
The reComputer J4012 handles RGB vision processing, LIDAR point cloud interpretation, sensor fusion, and the higher-level ROS 2 orchestration.
For real-time motion control, low-level motor drivers and STM32-NUCLEO microcontrollers handle wheel actuation and IMU feedback, offloading time-critical closed-loop control from the Jetson. This allows the Orin NX to focus on perception, planning, and manipulation.
This heterogeneous architecture allows each processor to handle the workloads best suited to its strengths.
Synchronizing Vision, LIDAR, and Motion
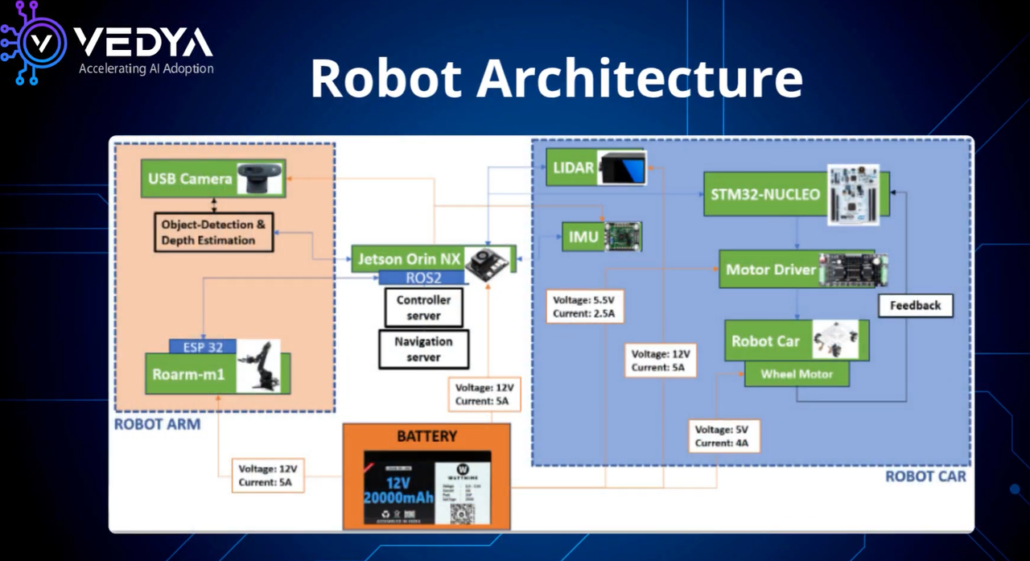
Mobile manipulation depends on accurate spatial and temporal alignment across sensing modalities.
If camera frames, LIDAR scans, and IMU motion data are captured at different moments, fusing them can produce inconsistent maps and unreliable manipulation decisions.
Vedya Labs uses ROS 2’s time synchronization and message-passing architecture to create a shared temporal and spatial reference across the sensing stack, allowing synchronized sensor data to be processed and fused by the edge AI platform in real time.
From Sensor Data to Physical Action
The overall workflow of Vedya Labs’ mobile manipulation platform can be summarized as:
Sense → Synchronize → Process → Fuse → Decide → Act
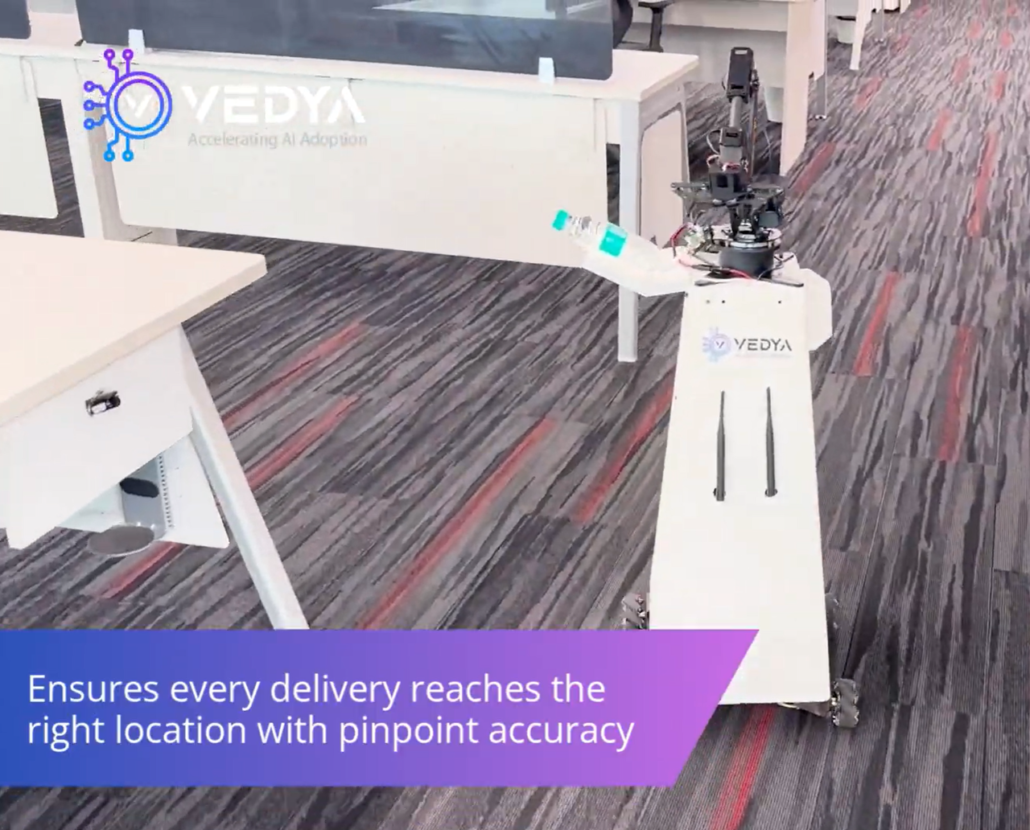
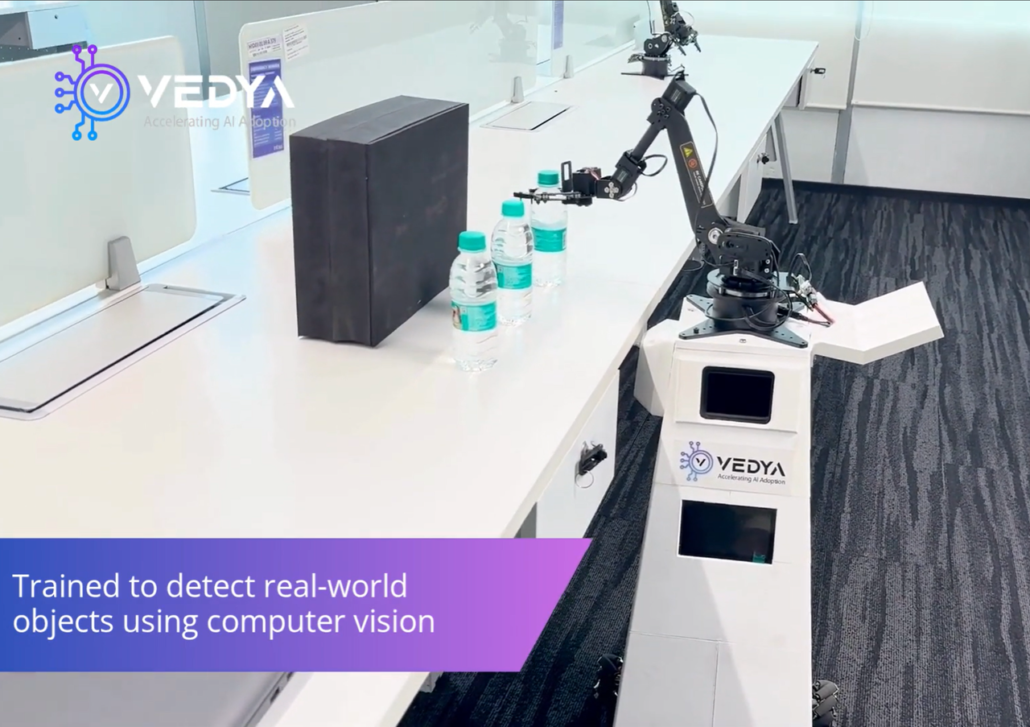
For example, when the perception system identifies a laundry basket, the robotic arm can be dynamically repositioned to grasp it based on the fused position estimate from camera, LIDAR, and IMU. The same architecture also enables the robot to respond to operator voice commands such as “Start Cycle” or “Emergency Stop” while continuing to navigate safely.
Why Edge AI Matters
Service robots generate large amounts of sensor and video data. Sending every stream to the cloud would introduce latency, bandwidth requirements, and connectivity dependencies that don’t work in real-world deployments.
By processing data locally, the reComputer J4012 enables:
- low-latency sensor processing and motion planning;
- GPU-accelerated AI workloads for vision and perception;
- reduced dependence on cloud connectivity;
- integration of multiple sensing interfaces through a unified ROS 2 stack;
- flexible expansion for additional sensors, robotic arms, and accelerators.
Vedya Labs’ deployment demonstrates how an edge AI computer can become the central bridge between perception, AI models, sensor synchronization, and physical manipulation.
Key Outcomes
- Full Autonomy in Unstructured Spaces: The robot successfully navigates complex indoor environments with zero collisions, using LIDAR and IMU fusion for stable localization even when visual features are compromised by lighting.
- High-Accuracy Task Execution: Achieved over 95% success rate in object sorting and manipulation, driven by the low-latency feedback loop between the vision system and the robotic arm.
- Seamless Human-Robot Collaboration: The localized voice interface reduced interaction latency to under 300 ms and reliably recognized commands in environments with noise levels up to −10 dB SNR.
Explore reComputer J4012 and start building your next service robot application.
About Author
