NVIDIA Jetson Solution: Automotive Multi-Sensor Fusion with reComputer Robotics J4012
📋Automotive Multi-Sensor Fusion with reComputer Robotics J4012
Modern vehicles increasingly rely on cameras, LiDAR, radar, GNSS, IMUs, microphones, and other sensors to understand their surroundings. The challenge is not only collecting this data, but also connecting, synchronizing, processing, and fusing multiple sensor streams in real time.
Project Nightchrome explores this challenge through an automotive multi-sensor fusion platform for intelligent vehicle lighting. At the center of the system is the Seeed Studio reComputer Robotics J4012, powered by NVIDIA Jetson Orin NX 16GB, which serves as the main edge AI computer for vision processing, sensor integration, and higher-level fusion and control.
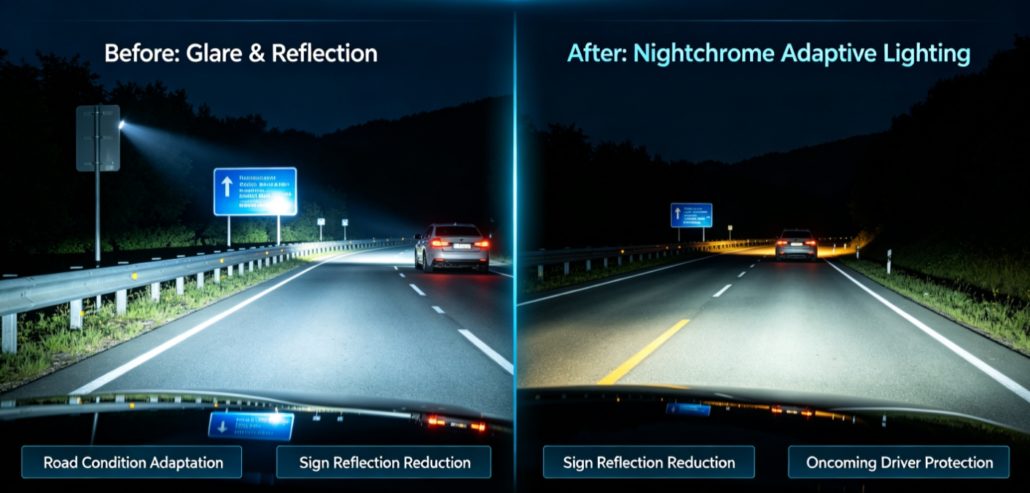
The Challenge: Real-Time Multi-Sensor Fusion
Each automotive sensor provides a different type of information.
RGB cameras capture rich visual details, event cameras react quickly to scene changes, GNSS and IMUs provide positioning and motion data, while radar, LiDAR, and microphones add complementary environmental information.
Bringing these sensors together creates several challenges:
- processing multiple high-bandwidth sensor streams;
- synchronizing data from different devices;
- supporting different interfaces and communication protocols;
- running AI workloads with low latency at the edge.
Project Nightchrome addresses these challenges while using the fused perception data to control an adaptive vehicle lighting system.
⚙️reComputer Robotics J4012 as the Central Edge AI Platform
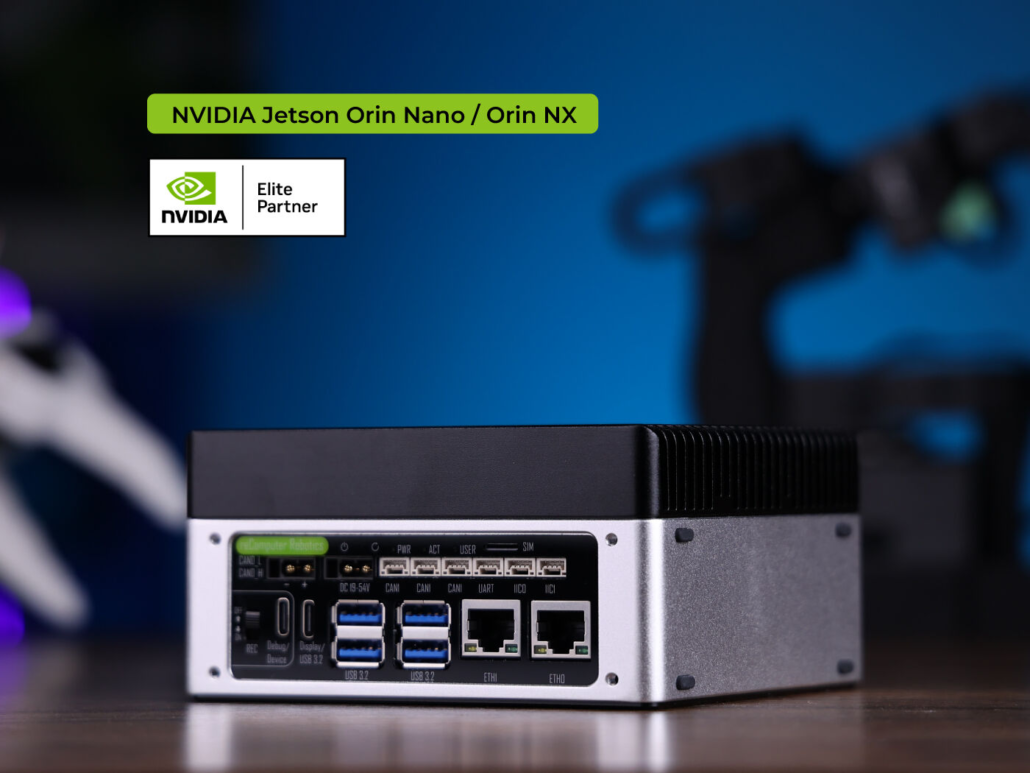
The reComputer Robotics J4012 provides the central computing platform for Project Nightchrome.
Built around NVIDIA Jetson Orin NX 16GB, it delivers up to 157 TOPS of AI performance for computer vision and edge AI workloads.
Beyond computing performance, the system provides interfaces including GMSL2, Gigabit Ethernet, USB, CAN, M.2, UART, and I²C, making it easier to connect cameras, sensors, networking devices, and additional AI accelerators.
For Project Nightchrome, the J4012 brings several key functions together:
Sensor Connectivity → AI Processing → Sensor Fusion → Control
Instead of building these capabilities from separate modules, developers can use the reComputer Robotics J4012 as an integrated Jetson edge AI platform.
A Heterogeneous Computing Architecture
Project Nightchrome distributes different workloads across different processors.
The reComputer Robotics J4012 handles RGB vision processing, sensor integration, and higher-level fusion.
For event-based vision, the system uses a BrainChip Akida AKD1000 neuromorphic processor connected through M.2. Offloading event-camera processing allows the Jetson Orin NX to focus on conventional vision, sensor fusion, and system control.
This heterogeneous architecture allows each processor to handle the workloads best suited to its strengths.
Synchronizing Multiple Sensors
Multi-sensor fusion also depends on accurate timing.
If camera, radar, LiDAR, and motion data are captured at different moments, combining them can produce an inaccurate representation of the environment.
Project Nightchrome uses a GNSS/GPS-based Precision Time Protocol (PTP) Grandmaster together with a Lattice CrossLink-NX FPGA for hardware timestamping.
This creates a shared timing reference across the sensing system, allowing synchronized data to be processed and fused by the edge AI platform.
From Sensor Data to Adaptive Lighting
Project Nightchrome uses the fused sensor information to control an adaptive LED lighting system.
The overall workflow can be summarized as:
Sense → Synchronize → Process → Fuse → Decide → Control
For example, when the perception system identifies an oncoming vehicle, selected regions of the lighting array can be dimmed or disabled to reduce glare while maintaining illumination elsewhere.
The system can also adapt lighting around reflective road signs and changing road conditions.
💡Why Edge AI Matters
Automotive multi-sensor systems generate large amounts of data. Sending every sensor stream to the cloud would introduce latency, bandwidth requirements, and connectivity dependencies.
By processing data locally, the reComputer Robotics J4012 enables:
- low-latency sensor processing;
- GPU-accelerated AI workloads;
- reduced dependence on cloud connectivity;
- integration of multiple sensing interfaces;
- flexible expansion for additional sensors and accelerators.
Project Nightchrome demonstrates how an edge AI computer can become the central bridge between sensors, AI models, synchronization, and physical control.
With NVIDIA Jetson computing and rich sensor connectivity, reComputer Robotics J4012 provides a practical platform for automotive multi-sensor fusion and other Physical AI applications.
Explore reComputer Robotics J4012 and start building your next multi-sensor Edge AI application.
About Author
